Software Overview
This section provides access to installation guides, downloads, release notes, and sample code for Robotic Suite.
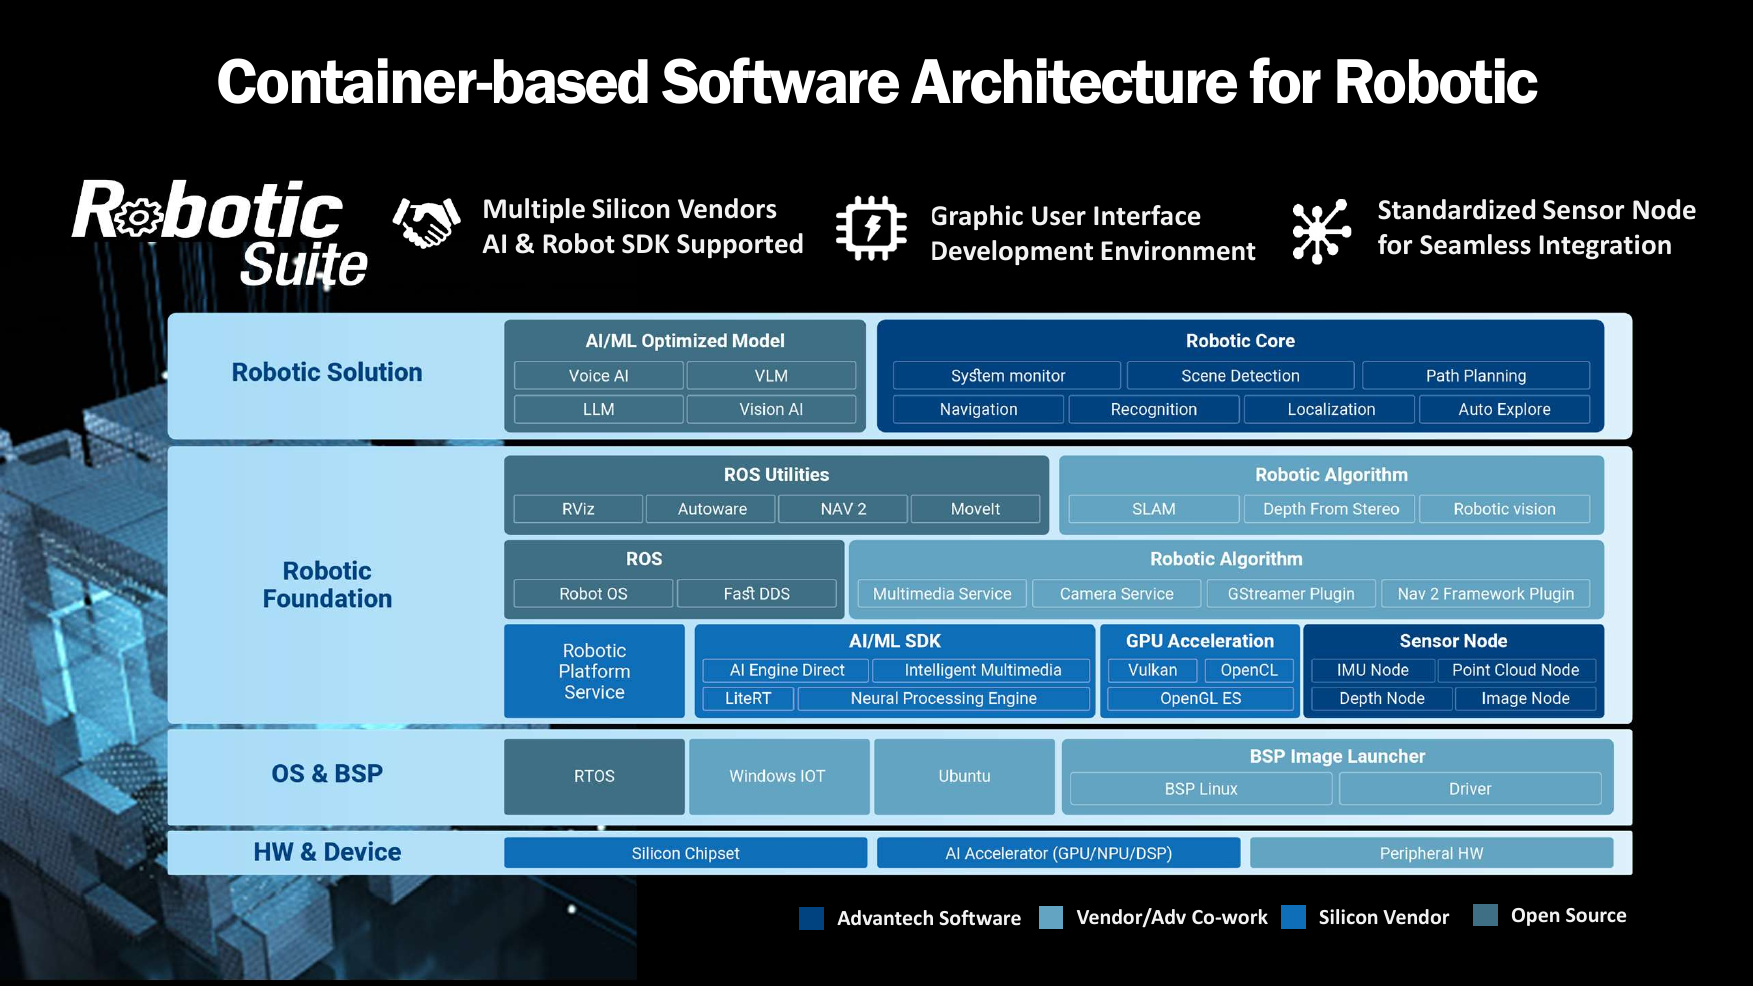
Blueprints
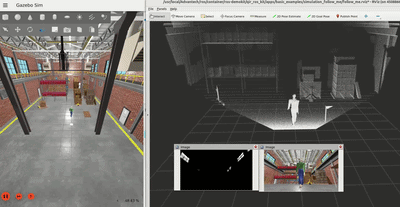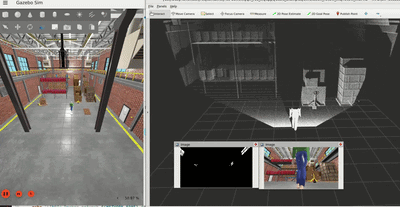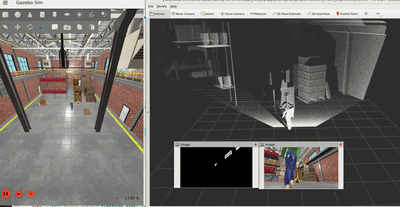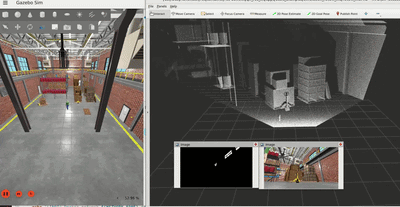
This section contains ready-to-run, teaching-oriented blueprints demonstrating common perception, AMR, and manipulator workflows.
Many blueprints include recorded ROS bags, allowing users to observe system behavior and understand the workflow without requiring physical sensors or robots.
The blueprints are organized into the following categories:
-
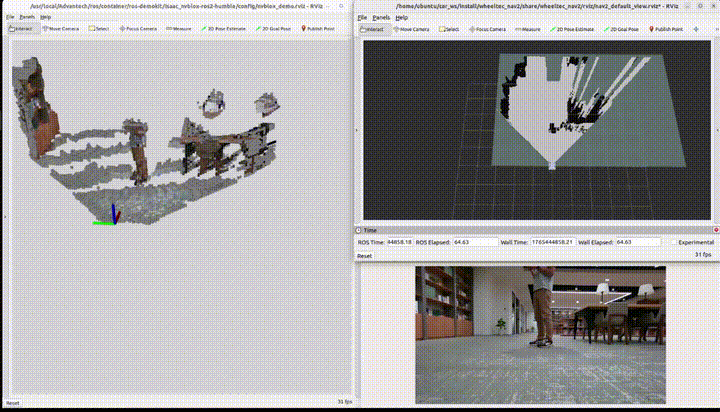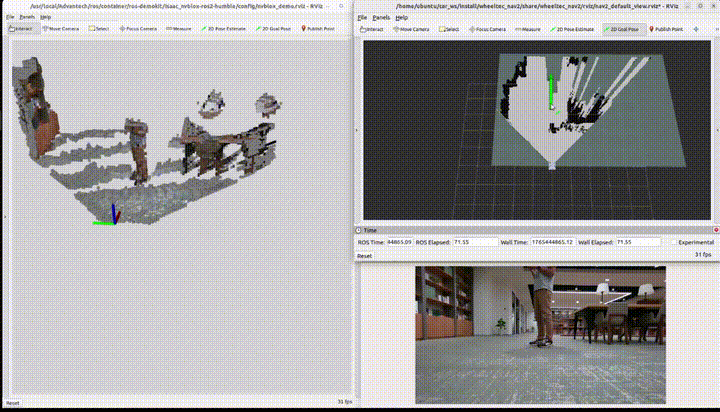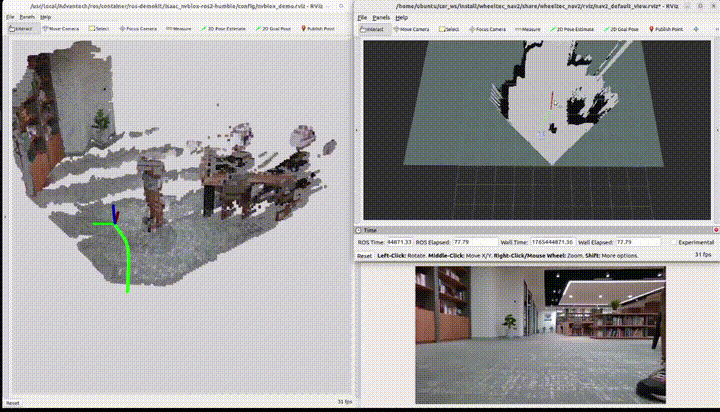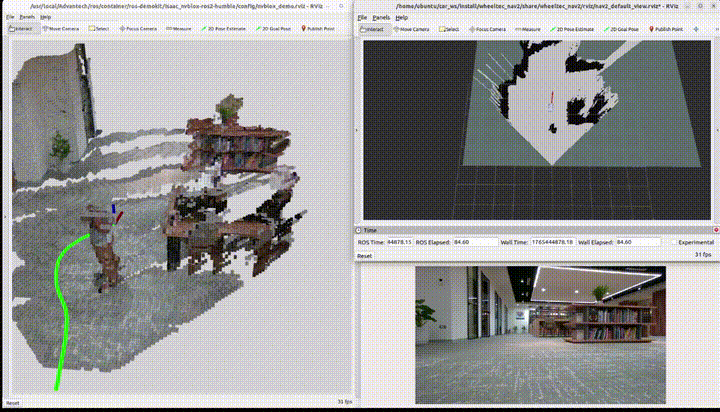
ISAAC ROS
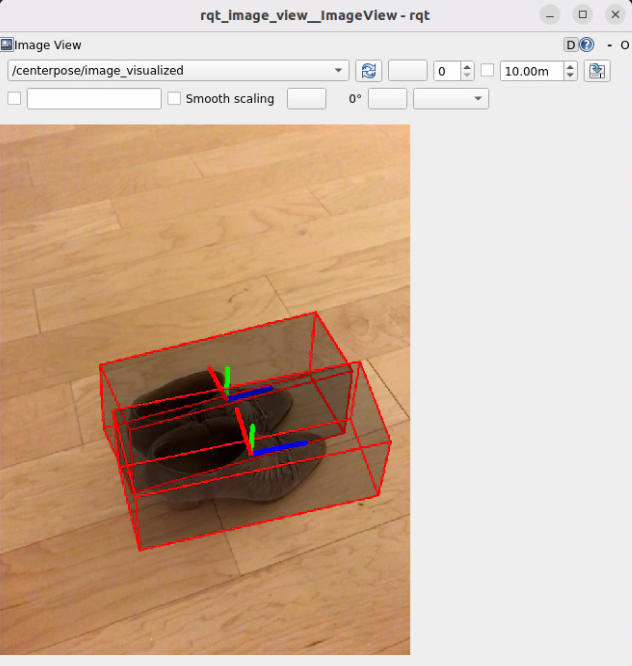
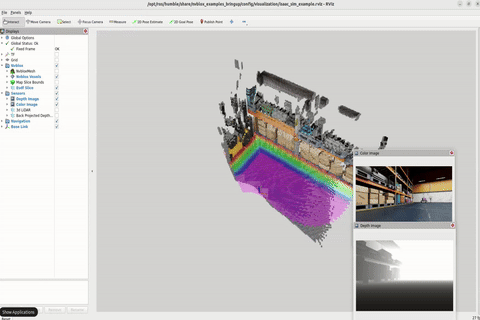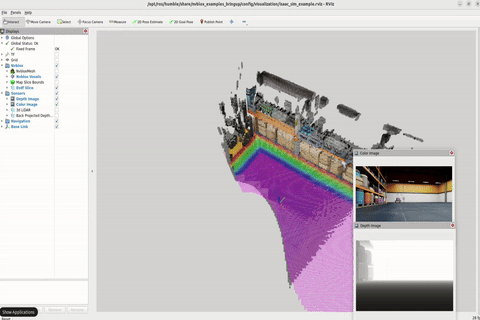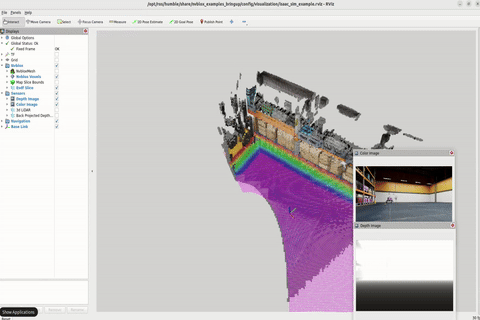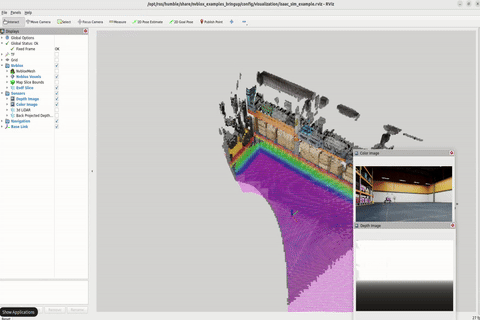
GPU-accelerated perception and advanced workflows using NVIDIA Isaac ROS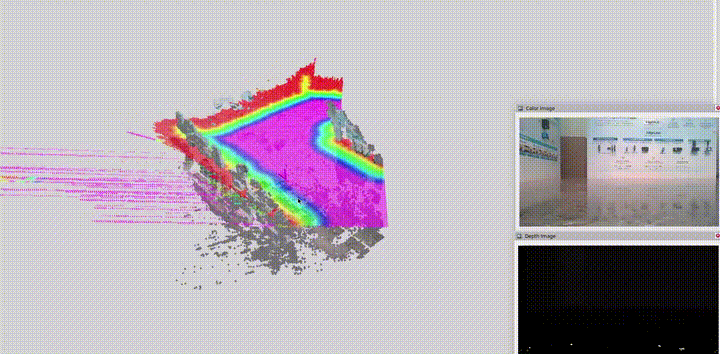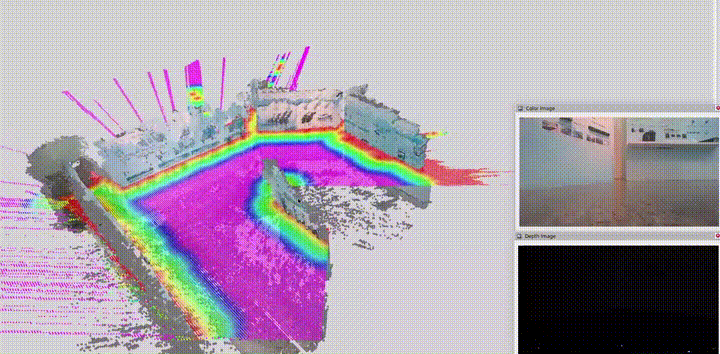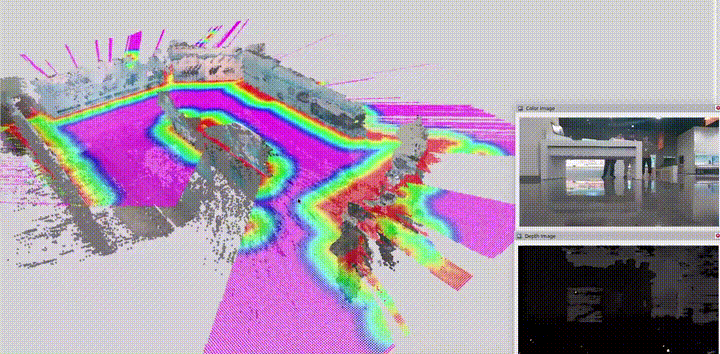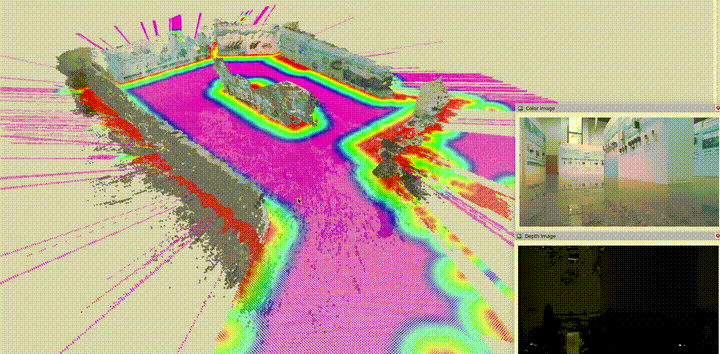
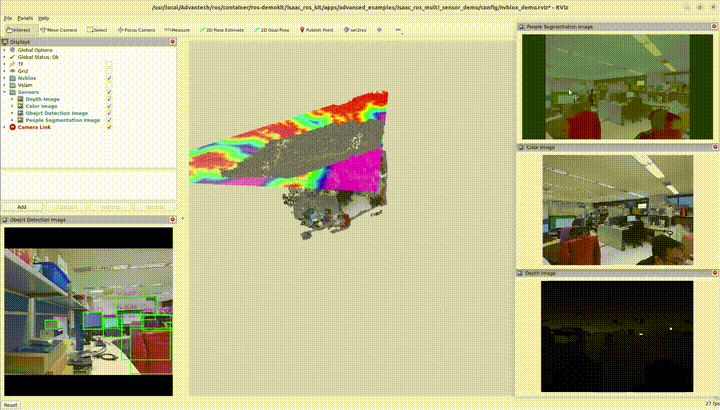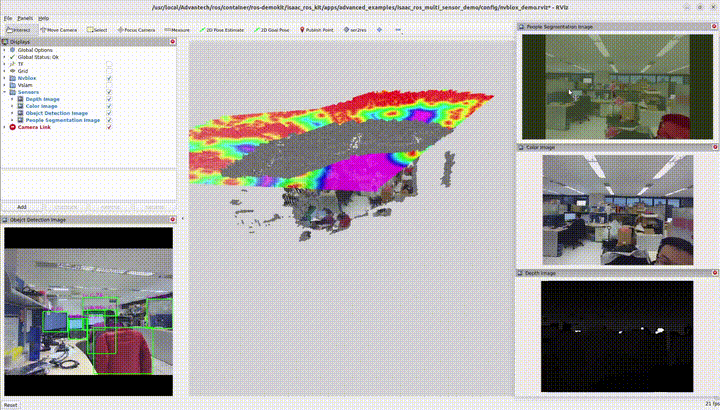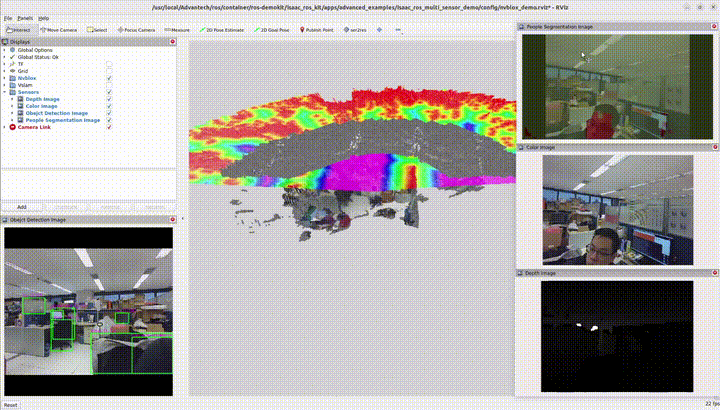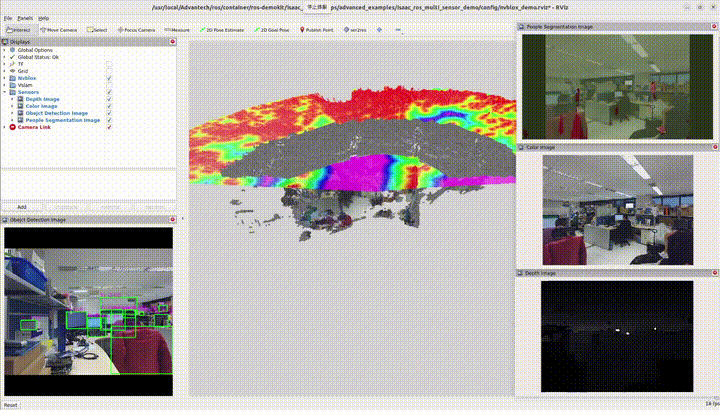
-
QIR ROS
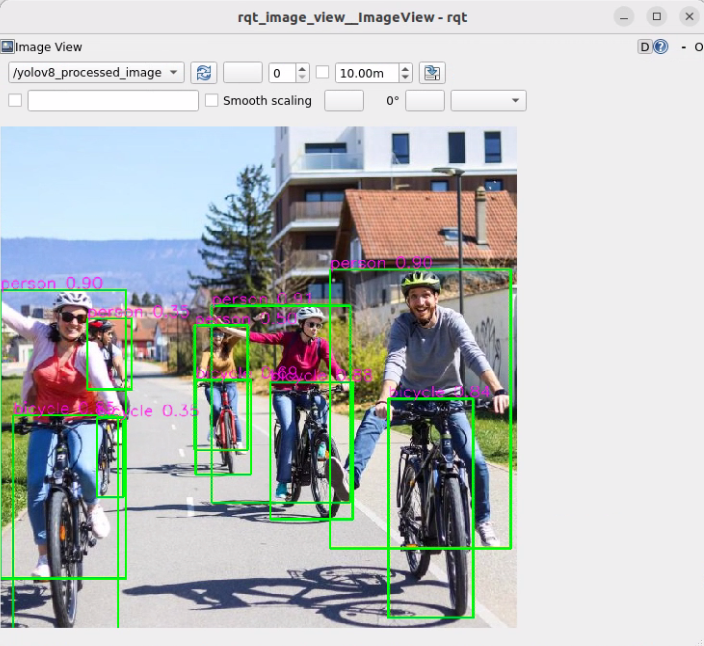
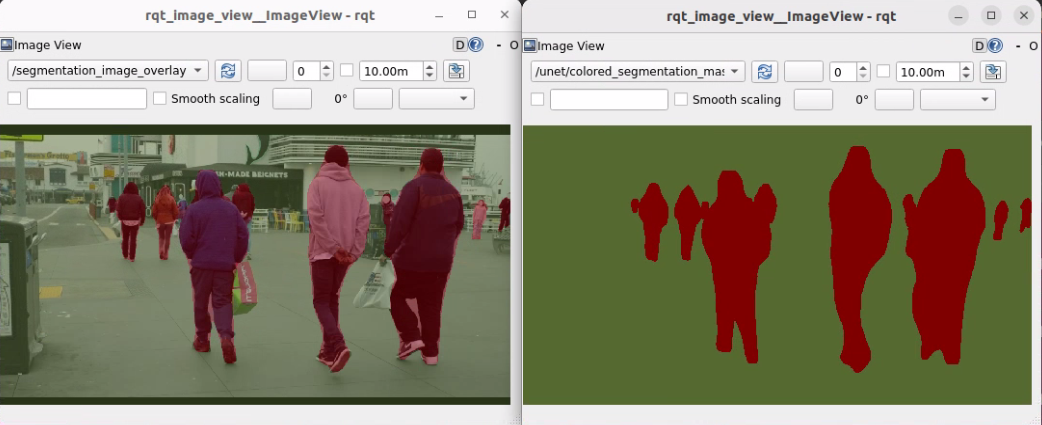
Qualcomm-accelerated perception workflows and teaching applications that demonstrate how multiple QIR ROS SDK packages can share sensor data and operate together.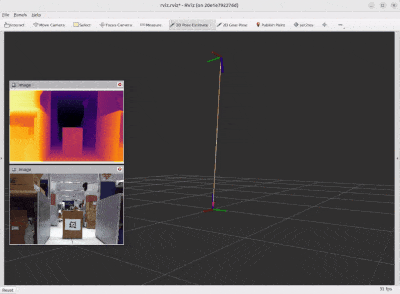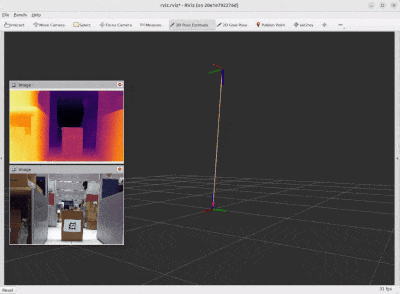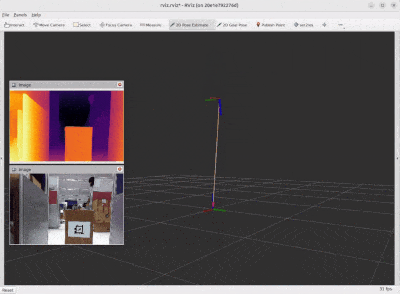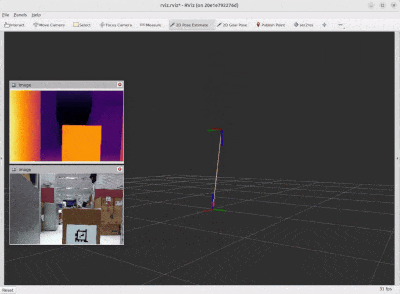
-
ROS Base
Core ROS 2 blueprints covering mapping, localization, and navigation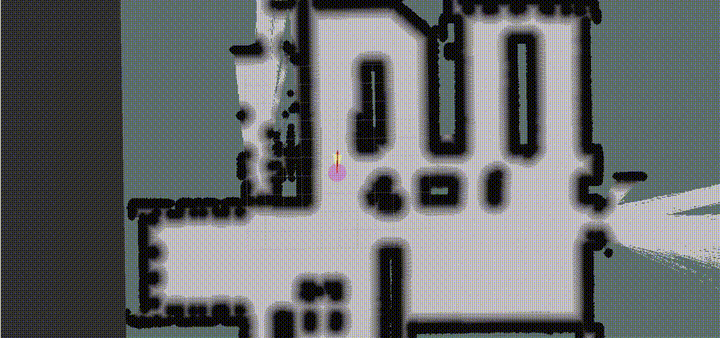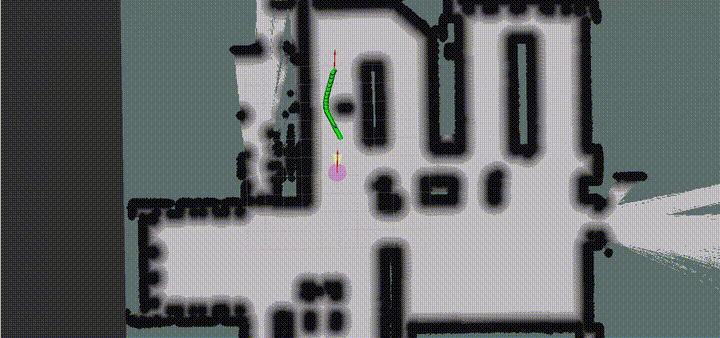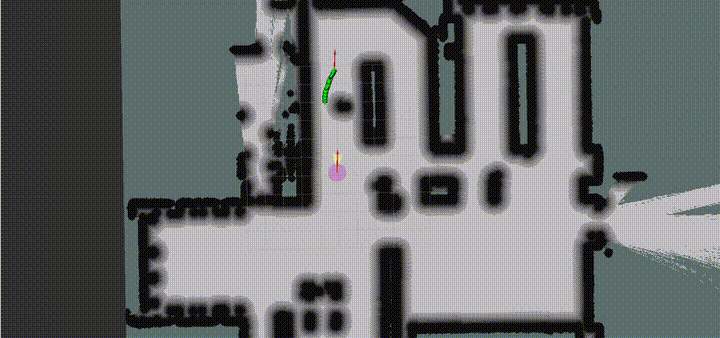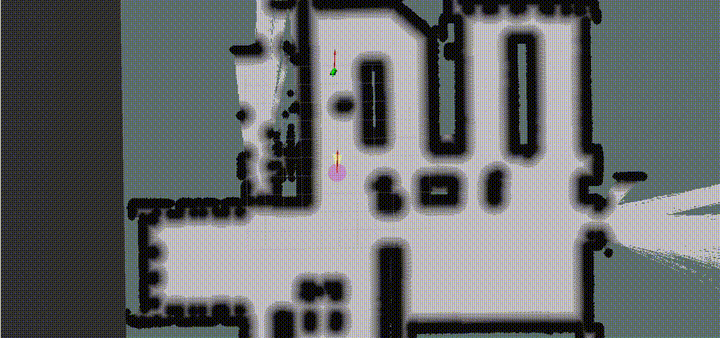
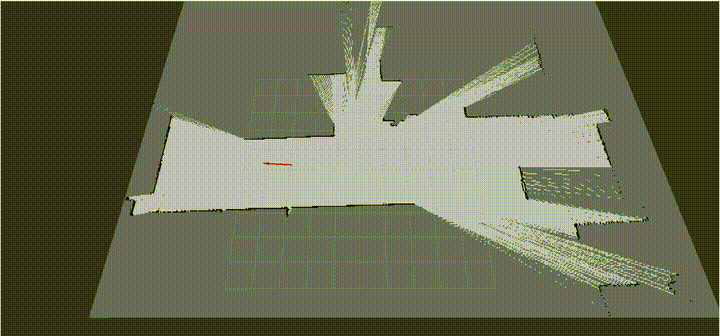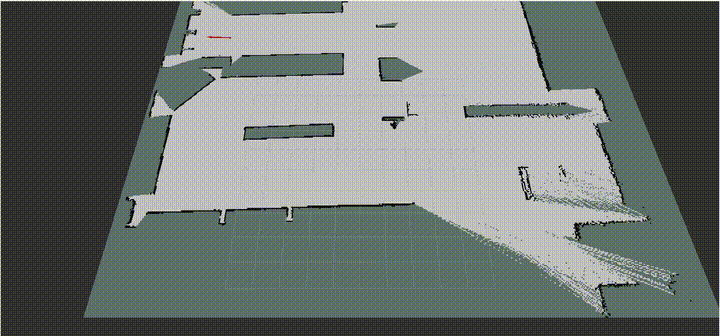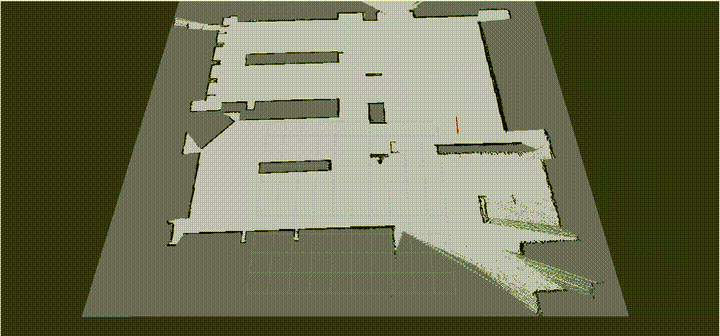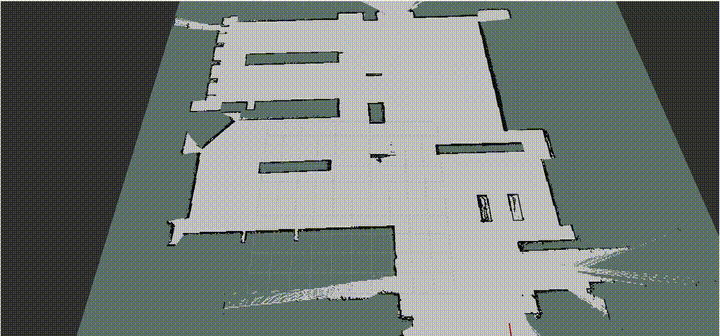
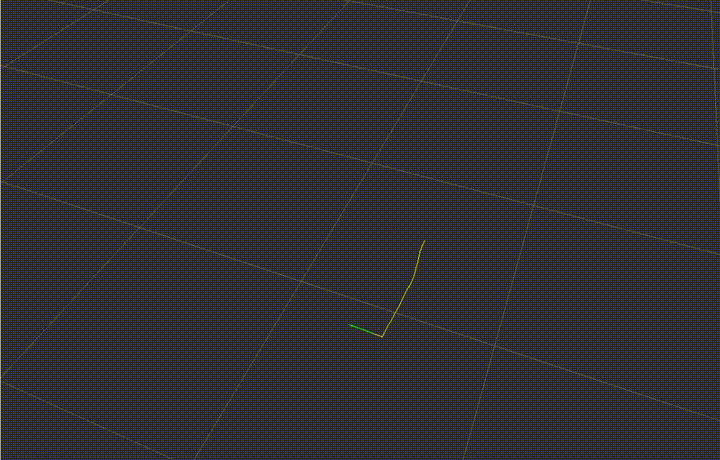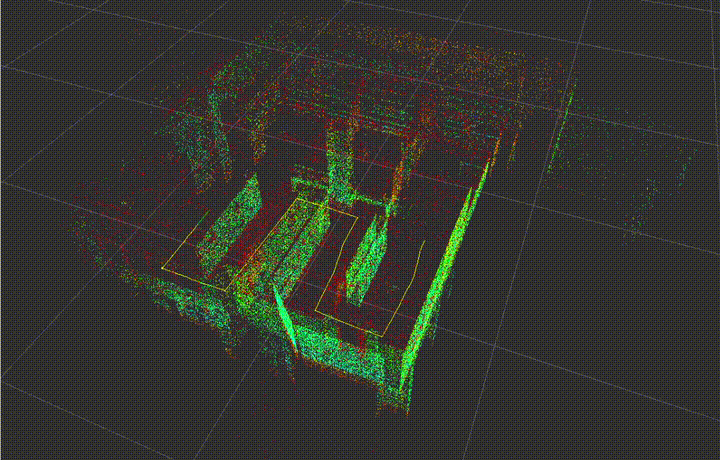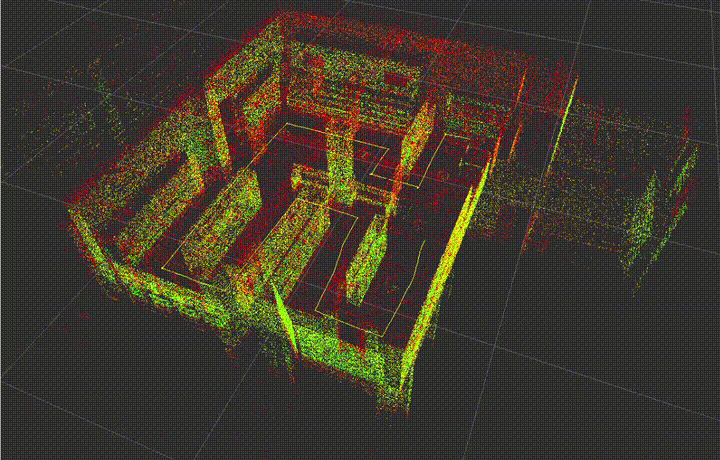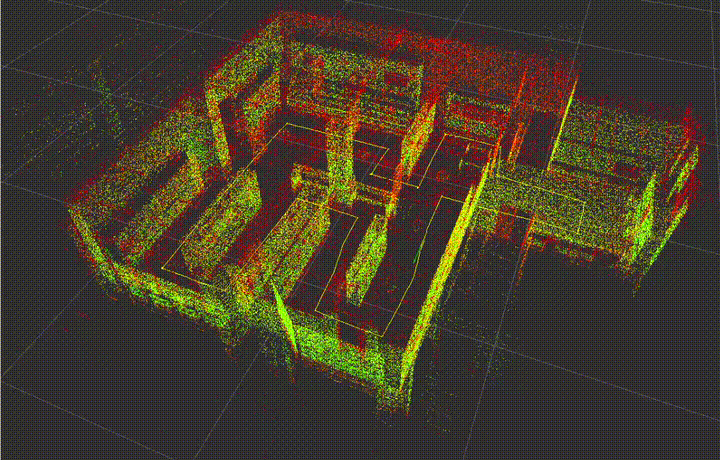
These blueprints can be used for learning, evaluation, and as a starting point for development.
Core Techniques
This section provides code-level tutorials for reusable robotics techniques.
Unlike the Blueprints section, these tutorials are not complete ROS 2 packages or application workflows. They focus on small, reusable building blocks that can be integrated into your own robotics applications.
The tutorials are organized by topic:
Vision
-
Color Profile Creation
Create reusable HSV color profiles for object detection tasks.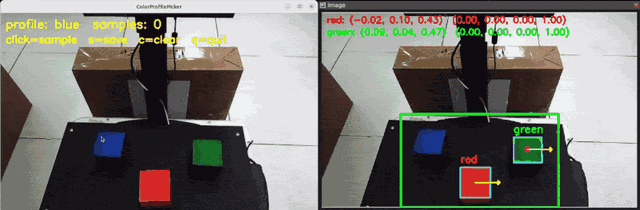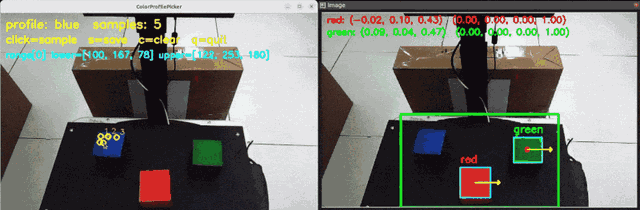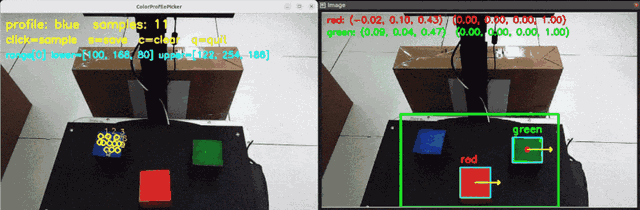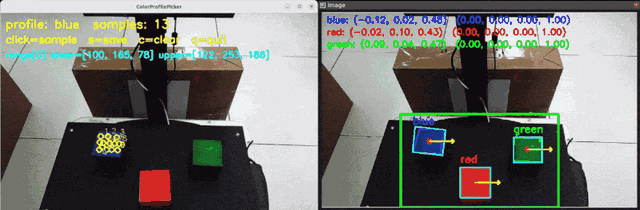
-
Color Block Detection & Position Estimation
Detect colored blocks and estimate their position using RGB and depth information.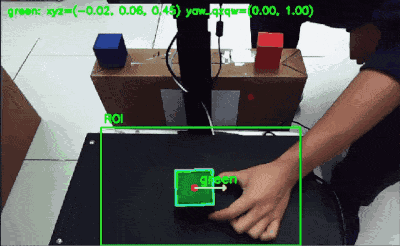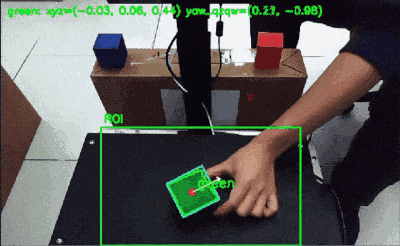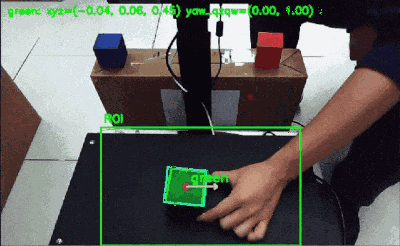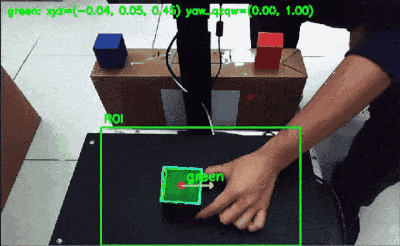
Development Environment
This section provides pre-configured environments for robotics development.
ISAAC ROS – Containerized environment for GPU-accelerated perception
QIR ROS – Containerized environment for QIR ROS SDK development and Qualcomm-accelerated robotics workloads
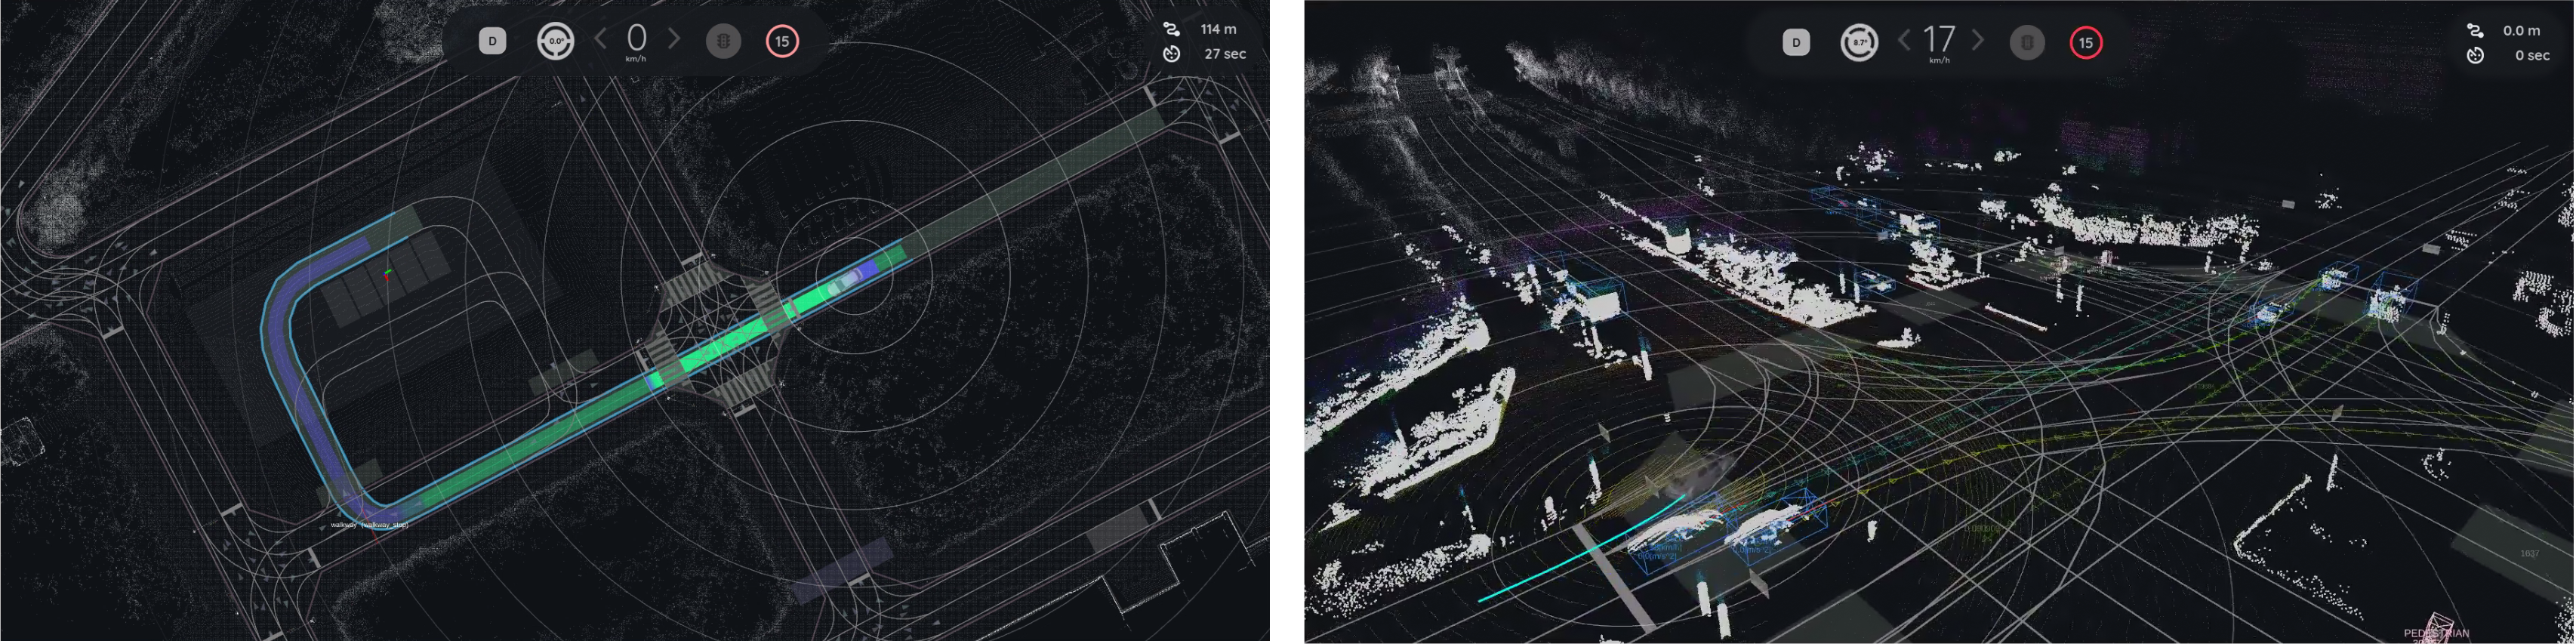
Autoware – Containerized stack for autonomous driving workflows
These environments are designed to reduce setup effort and accelerate development.