Robotic Core
This section provides code-level tutorials for reusable robotics techniques.
Unlike Example Workflows, these tutorials are not full ROS 2 packages or complete application demos. They focus on small, reusable building blocks that can be integrated into your own robotics applications.
The tutorials are organized by topic:
Vision
-
Color Profile Creation
Create reusable HSV color profiles for object detection tasks.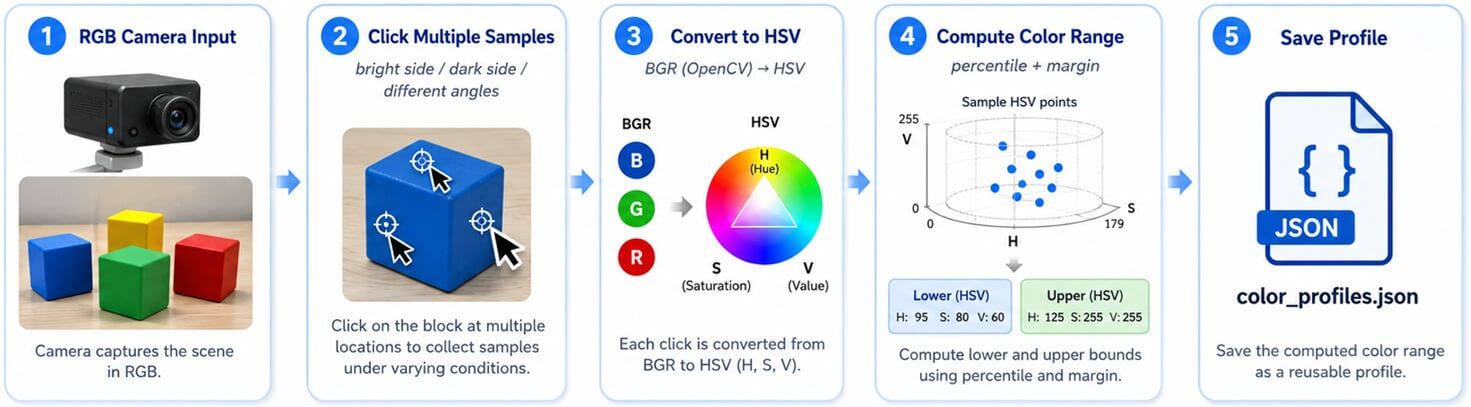
-
Color Block Detection & Position Estimation
Detect colored blocks and estimate their position using RGB and depth information.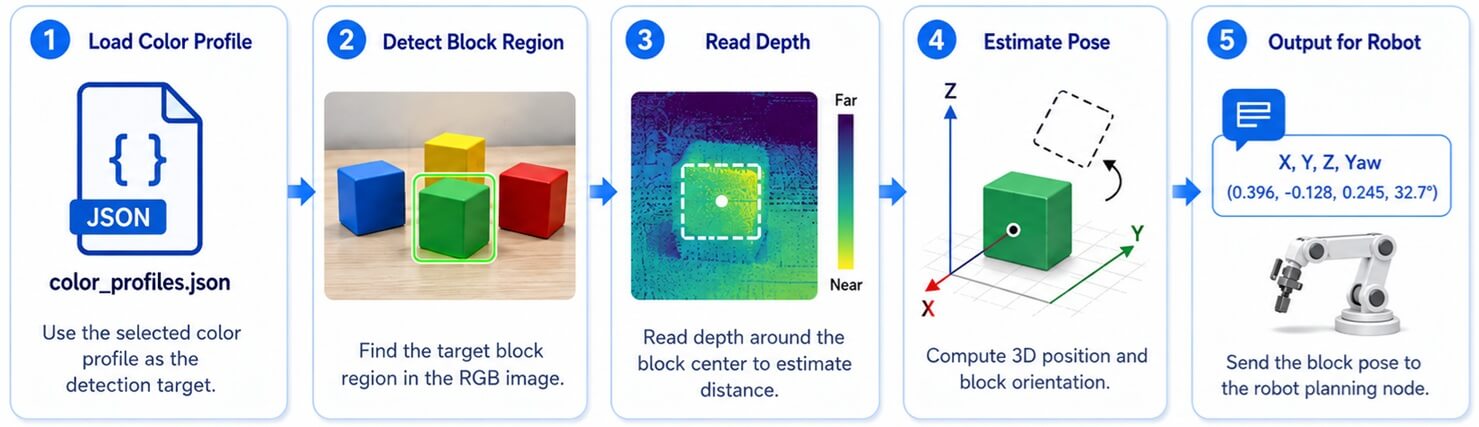
Use these tutorials when you want to understand and reuse the core logic behind a robotic application, such as color selection, object detection, depth-based position estimation, and pose generation.